Kraut /kʁaʊt/
Real-Time Crowd Simulation
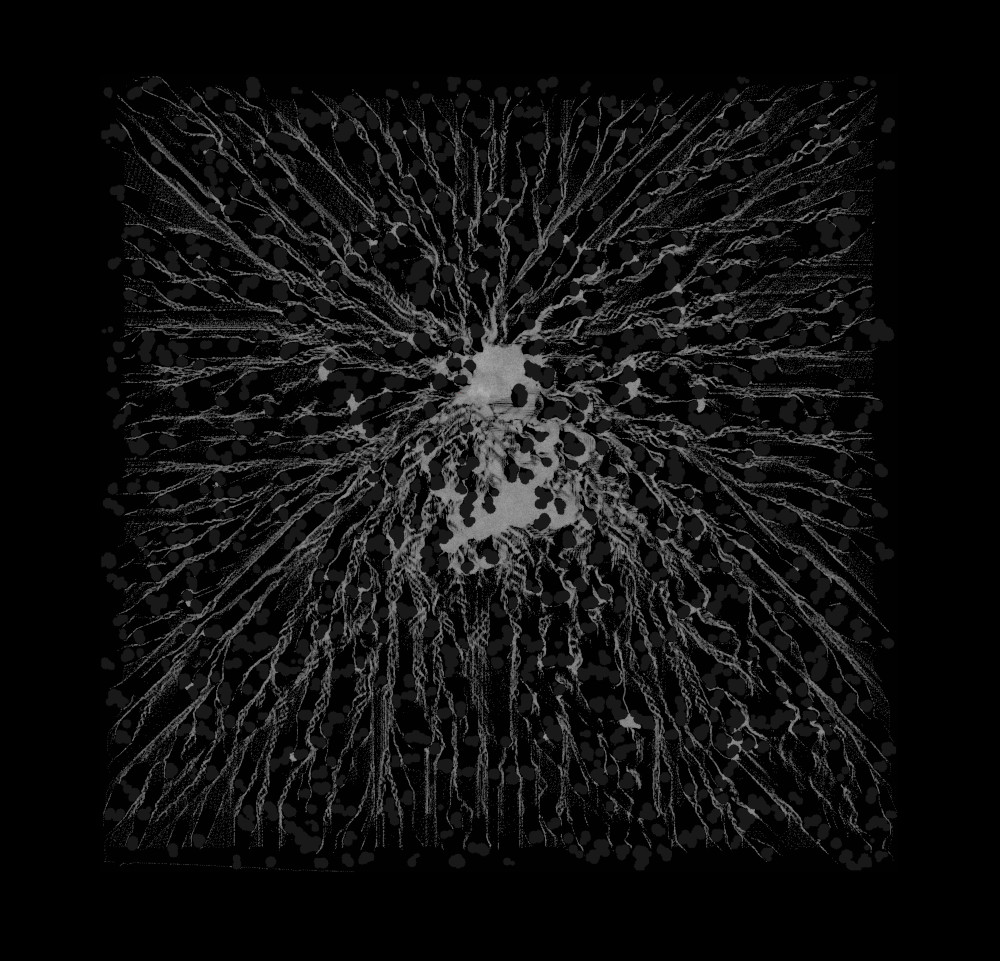
A lightweight crowd simulation library for native platforms and the browser. Try the WebAssembly build or download a prebuilt SDK; the recorded Linux run uses 100,000 agents on a tile map.
- Reference run
- 100,000 agents
- Simulation step
- 30 Hz fixed step
- Runtime
- Native + WebAssembly
Video
Native reference run
Recorded on Linux with a fixed 30 Hz simulation step. The run displays 100,000 agents using the default solver.
Implementation
Simulation pipeline
The implementation uses four main stages for routing, neighbor lookup, local avoidance, and congestion handling.
-
01
Reverse flow field
One shared field provides global routing across the tile map.
-
02
Packed spatial bins
Nearby agents are found quickly without scanning the whole crowd.
-
03
Bounded ORCA avoidance
A bounded local solve computes collision-avoiding velocities.
-
04
Density + clearance fields
Density and obstacle clearance influence movement in congested areas.